Yuer Gao · Robotics Researcher · Underwater Embodied Intelligence
Seeking Postdoctoral
Research Opportunities
I build intelligent marine robots that can perceive, reason, and act in challenging underwater environments.
At a glance
Research with real-world impact
What I do
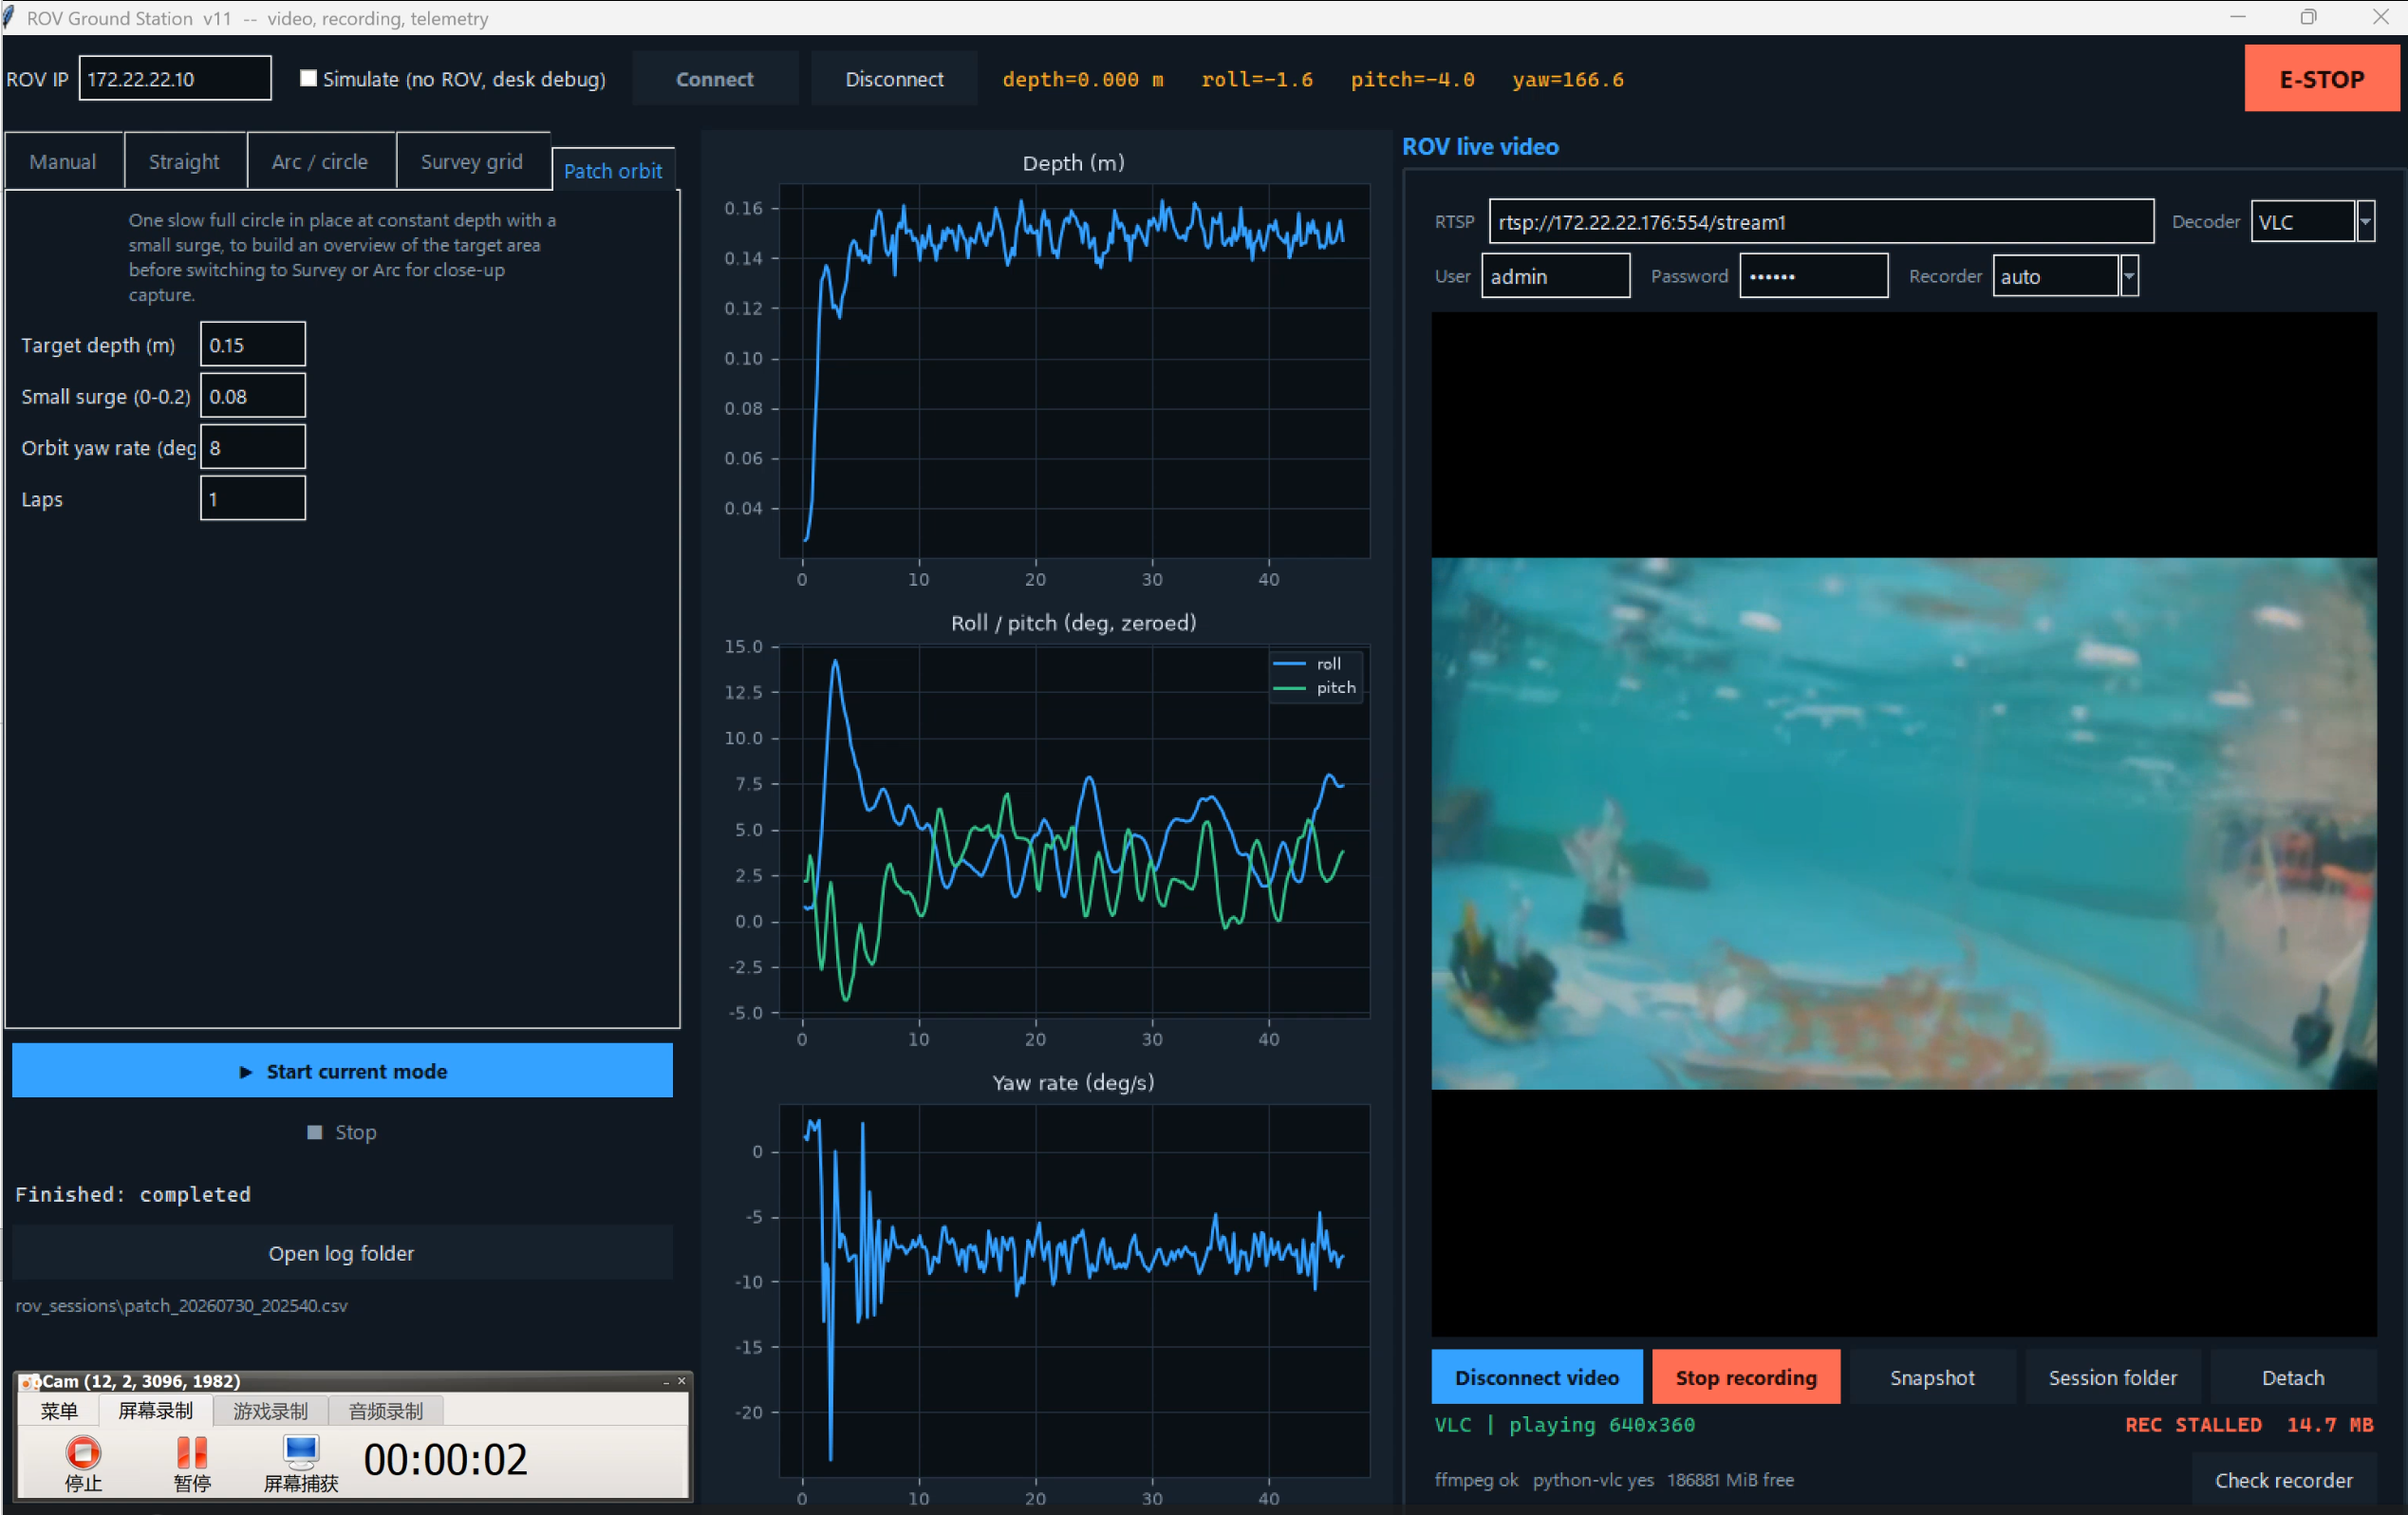
I build complete underwater robotic systems, spanning perception, planning, control, and real-world deployment.
Selected work
From algorithms to underwater deployment
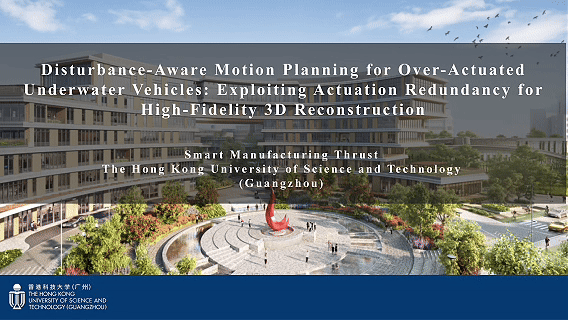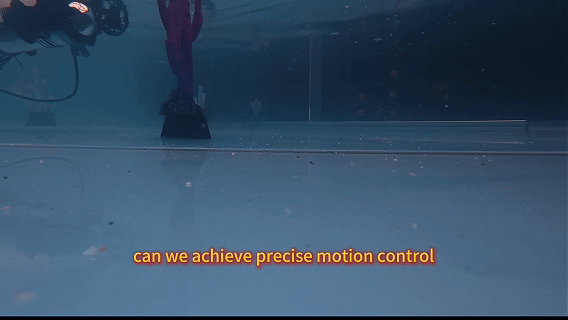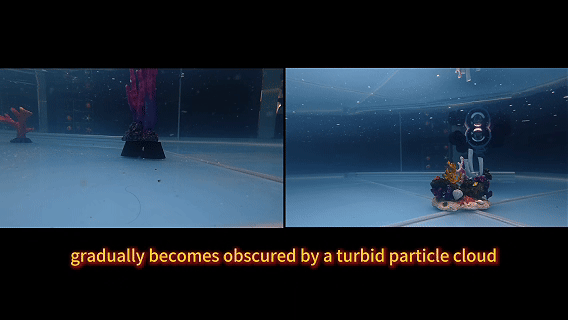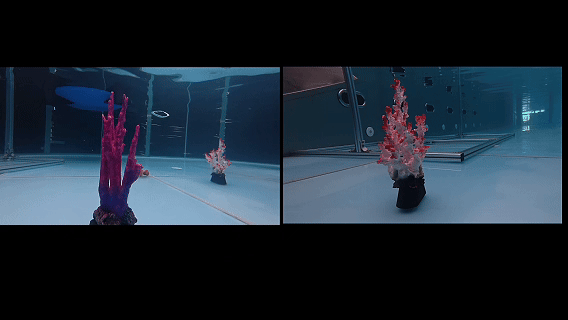
Disturbance-Aware Autonomy
Motion planning for over-actuated ROVs that protects fragile targets while maintaining reliable 3D reconstruction.
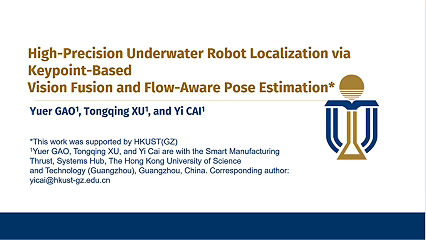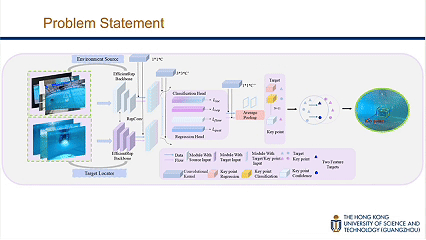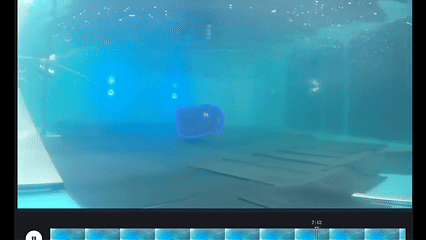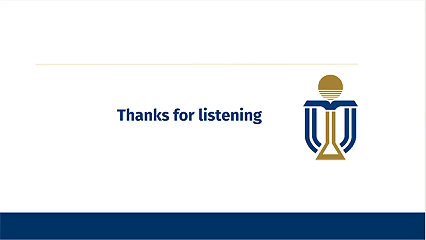
Real-Time Underwater Localization
Vision–optical fusion and monocular localization designed for turbidity, motion, and changing underwater visibility.
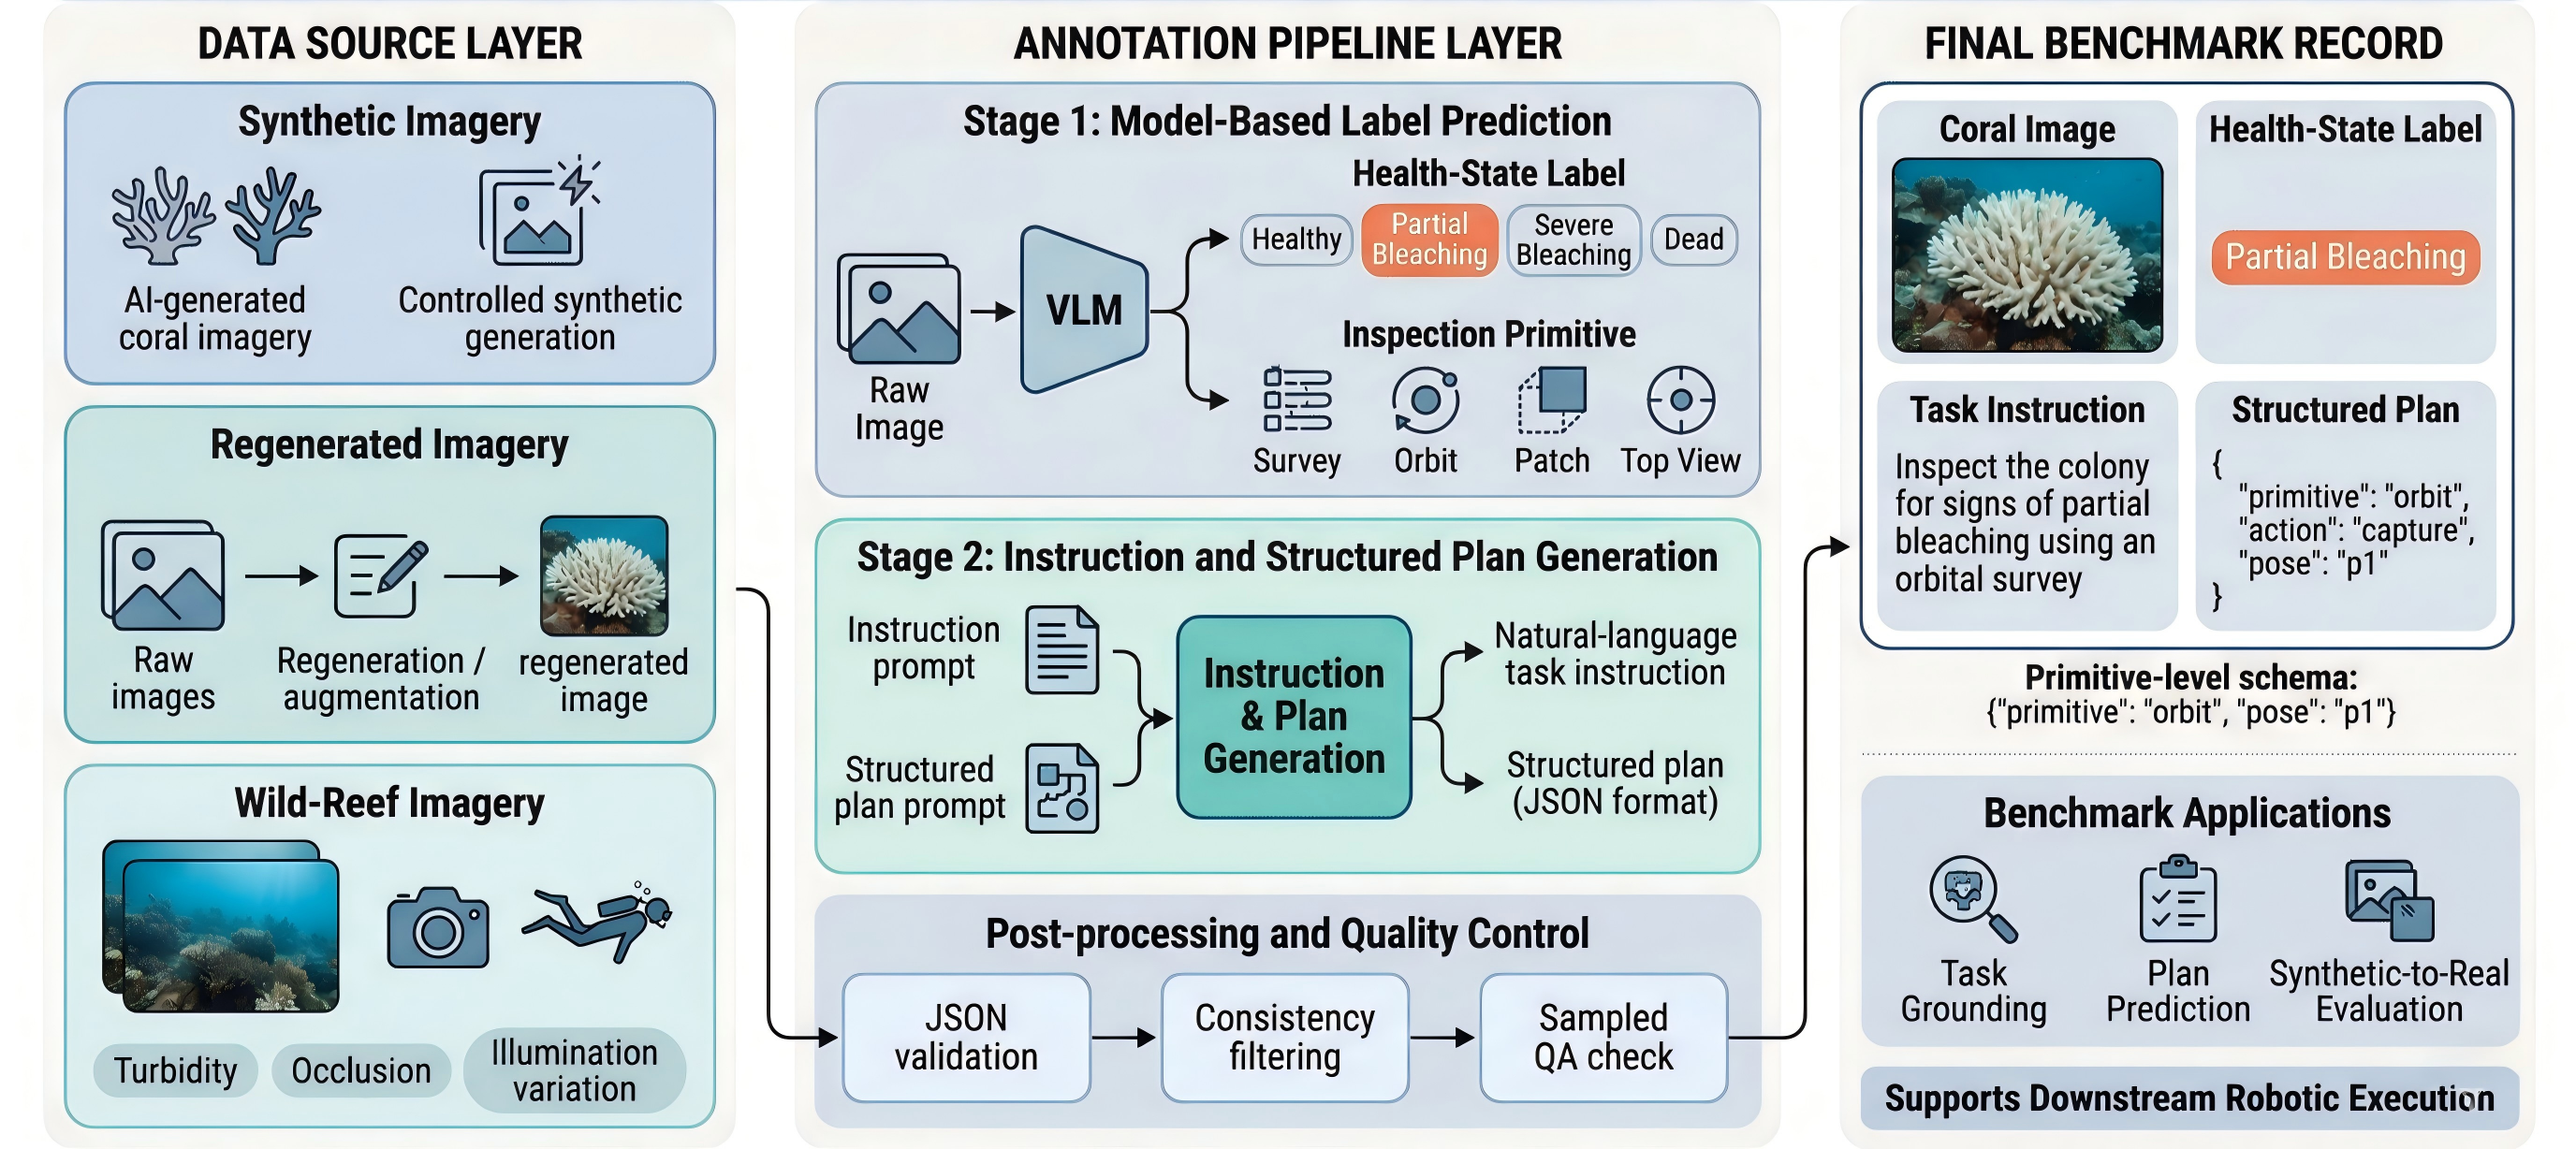
CoralVLM
A task-oriented vision-language benchmark connecting visual reasoning with actionable coral-inspection plans.
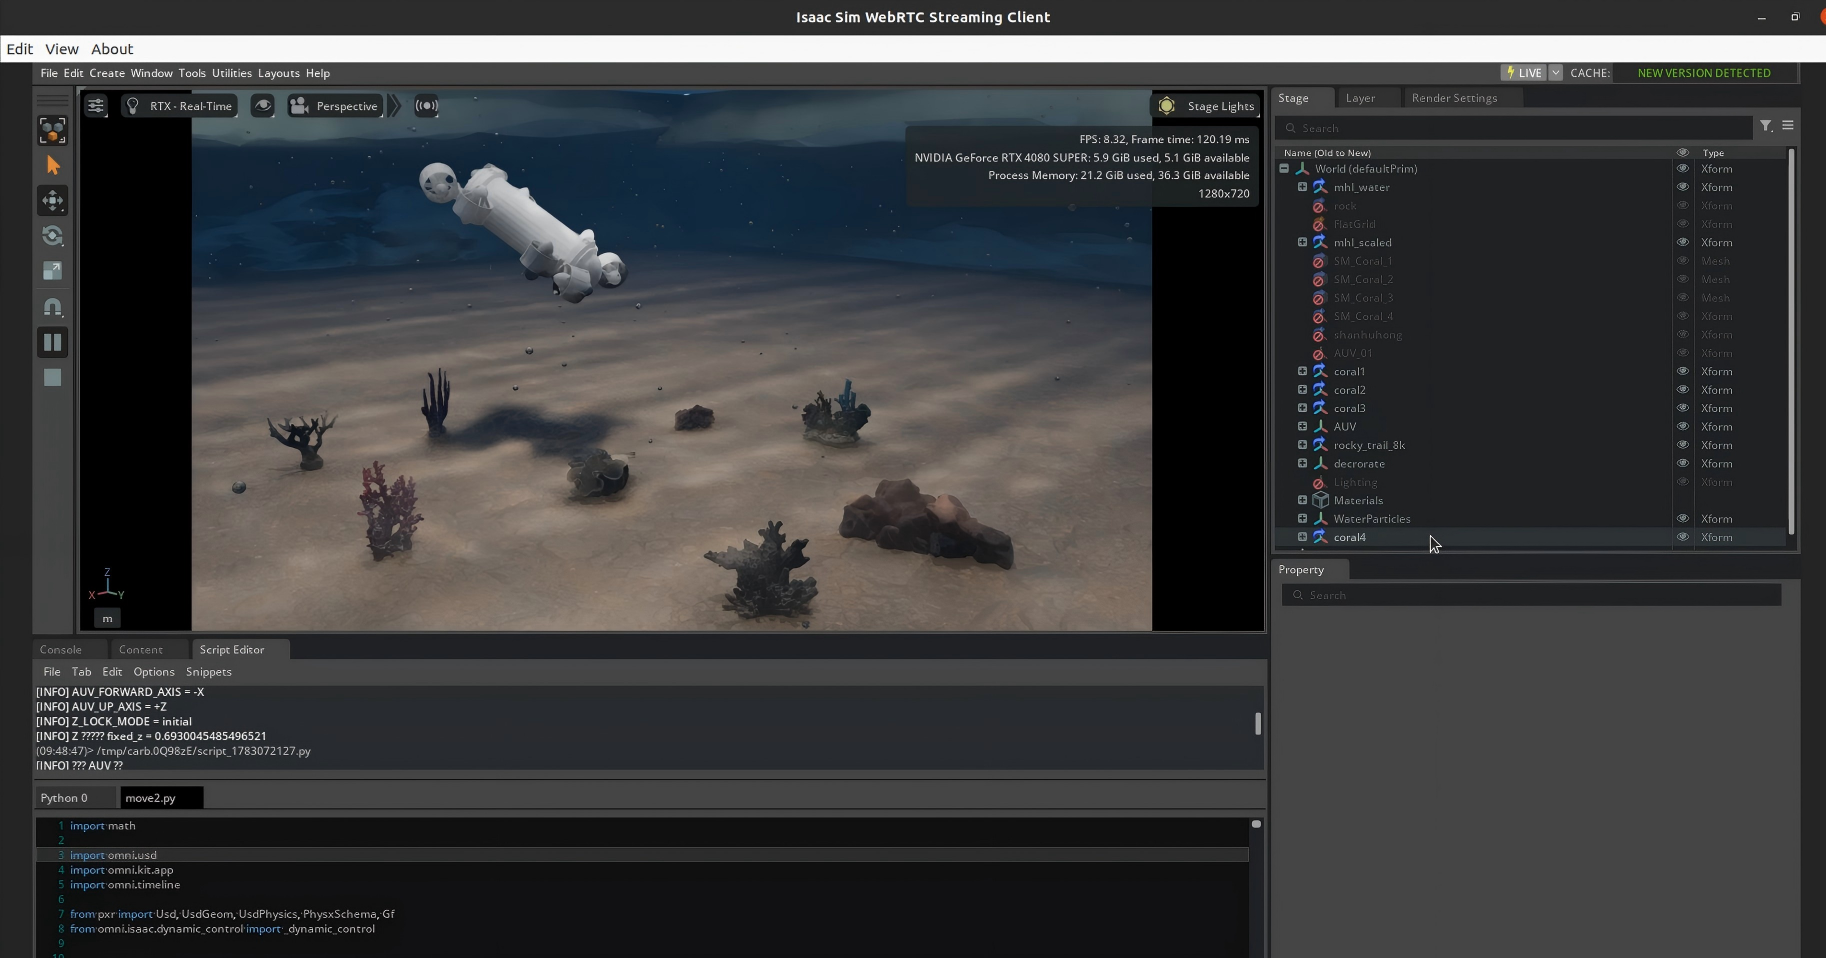
Ocean Isaac Sim & ROV Platform
An integrated research stack for simulation, telemetry, control, experiment recording, and sim-to-real evaluation.
Research output
Selected Publications
Published
A Vision-Based Operator-Guided Framework for Close-Range ROV Inspection of Coral Colonies via Multi-View 3D Anchoring
Yuer Gao, J. Luo, Y. Cai · Paper
Real-Time Millimeter-Accurate Underwater Pose Estimation via Tightly-Coupled Fusion of Vision and Optical Tracking
Yuer Gao, T. Xu, Y. Cai · Paper
MULoc: Robust Monocular Visual Localization for Underwater Robots via Multi-modal Feature Fusion
Yuer Gao, Y. Cai
Minimum-Snap Trajectory Optimization for Underwater Manipulator
Yuer Gao, T. Xu, Y. Cai
Under Review / Submitted
Disturbance-Aware Motion Planning for Over-Actuated Underwater Vehicles Exploiting Actuation Redundancy for High-Fidelity 3D Reconstruction
Yuer Gao, T. Xu, Q. Liu, Y. Cai
Bidirectionally Coupled Global–Local Path Planning for 3D Underwater Navigation in Ocean Currents
Yuer Gao, Y. Cai
CoralVLM: A Task-Oriented Vision-Language Benchmark Toward Underwater Embodied Coral Reef Inspection
Yuer Gao, Y. Zhao, Y. Cai
Background
Education & recognition
Education
Ph.D., Smart Manufacturing
HKUST(Guangzhou), 2023–2026 (expected)
M.S., Control Science and Engineering
Xi'an University of Technology, 2021–2023
B.E., Automation
Xi'an University of Technology, 2017–2021
Selected recognition
National Scholarship
Ministry of Education, China · 2022
China Robotics & AI Competition
First Prize · 2022
Model Mark Competition
Third Prize, Team Leader · 2024
Beyond research
What keeps me curious
Beyond the lab, I enjoy exploring oceans, photography, tennis, and museums.
I am fascinated by how intelligent systems can help us understand and protect the natural world.
Let’s work together
Let’s collaborate on marine robotics and embodied intelligence.
I would be glad to discuss postdoctoral positions, research scientist roles, and research collaborations.